Xun Kyrie Yang
Robotics · Whole-body control · Reinforcement learning
I am Xun Kyrie Yang, a visiting student in the ARG at the Oxford Robotics Institute, supervised by Prof. Ioannis Havoutis.
I completed my M.Phil. in Artificial Intelligence at The Hong Kong University of Science and Technology (Guangzhou) in October 2026, supervised by Prof. Junwei Liang. Previously, I received my B.Eng. in Automation from Harbin Institute of Technology, Shenzhen.
My research focuses on humanoid robots, whole-body control, and reinforcement learning. I am interested in combining perception, motion imitation, and learned world models to enable agile physical interaction and collaborative loco-manipulation.
I am currently working on CatchItMan, a perception-driven framework for humanoid ball catching, and MultiMimic, which explores coordinated multi-humanoid loco-manipulation. My previous work includes humanoid tennis, safe locomotion, autonomous loco-manipulation, and whole-body teleoperation.
Research in action
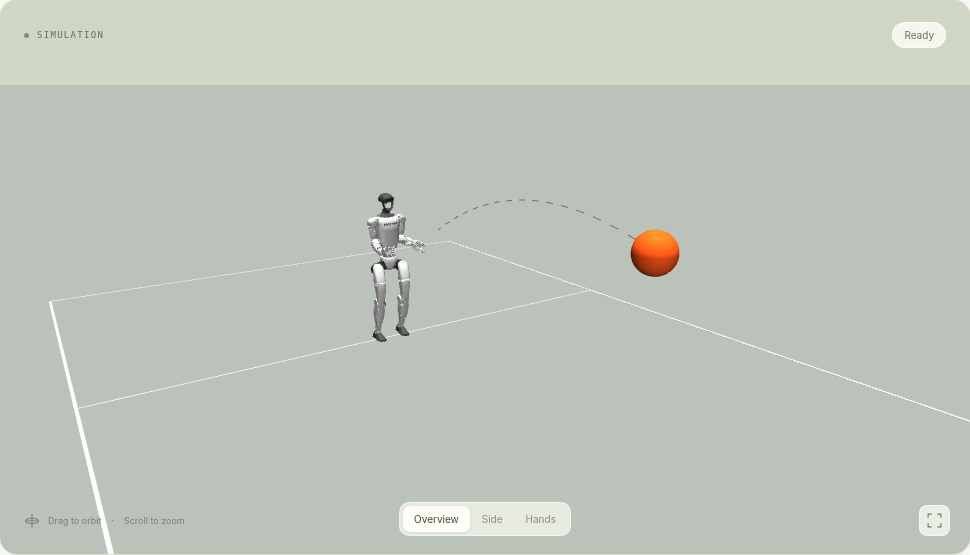
Humanoid ball catching · Try the interactive demo
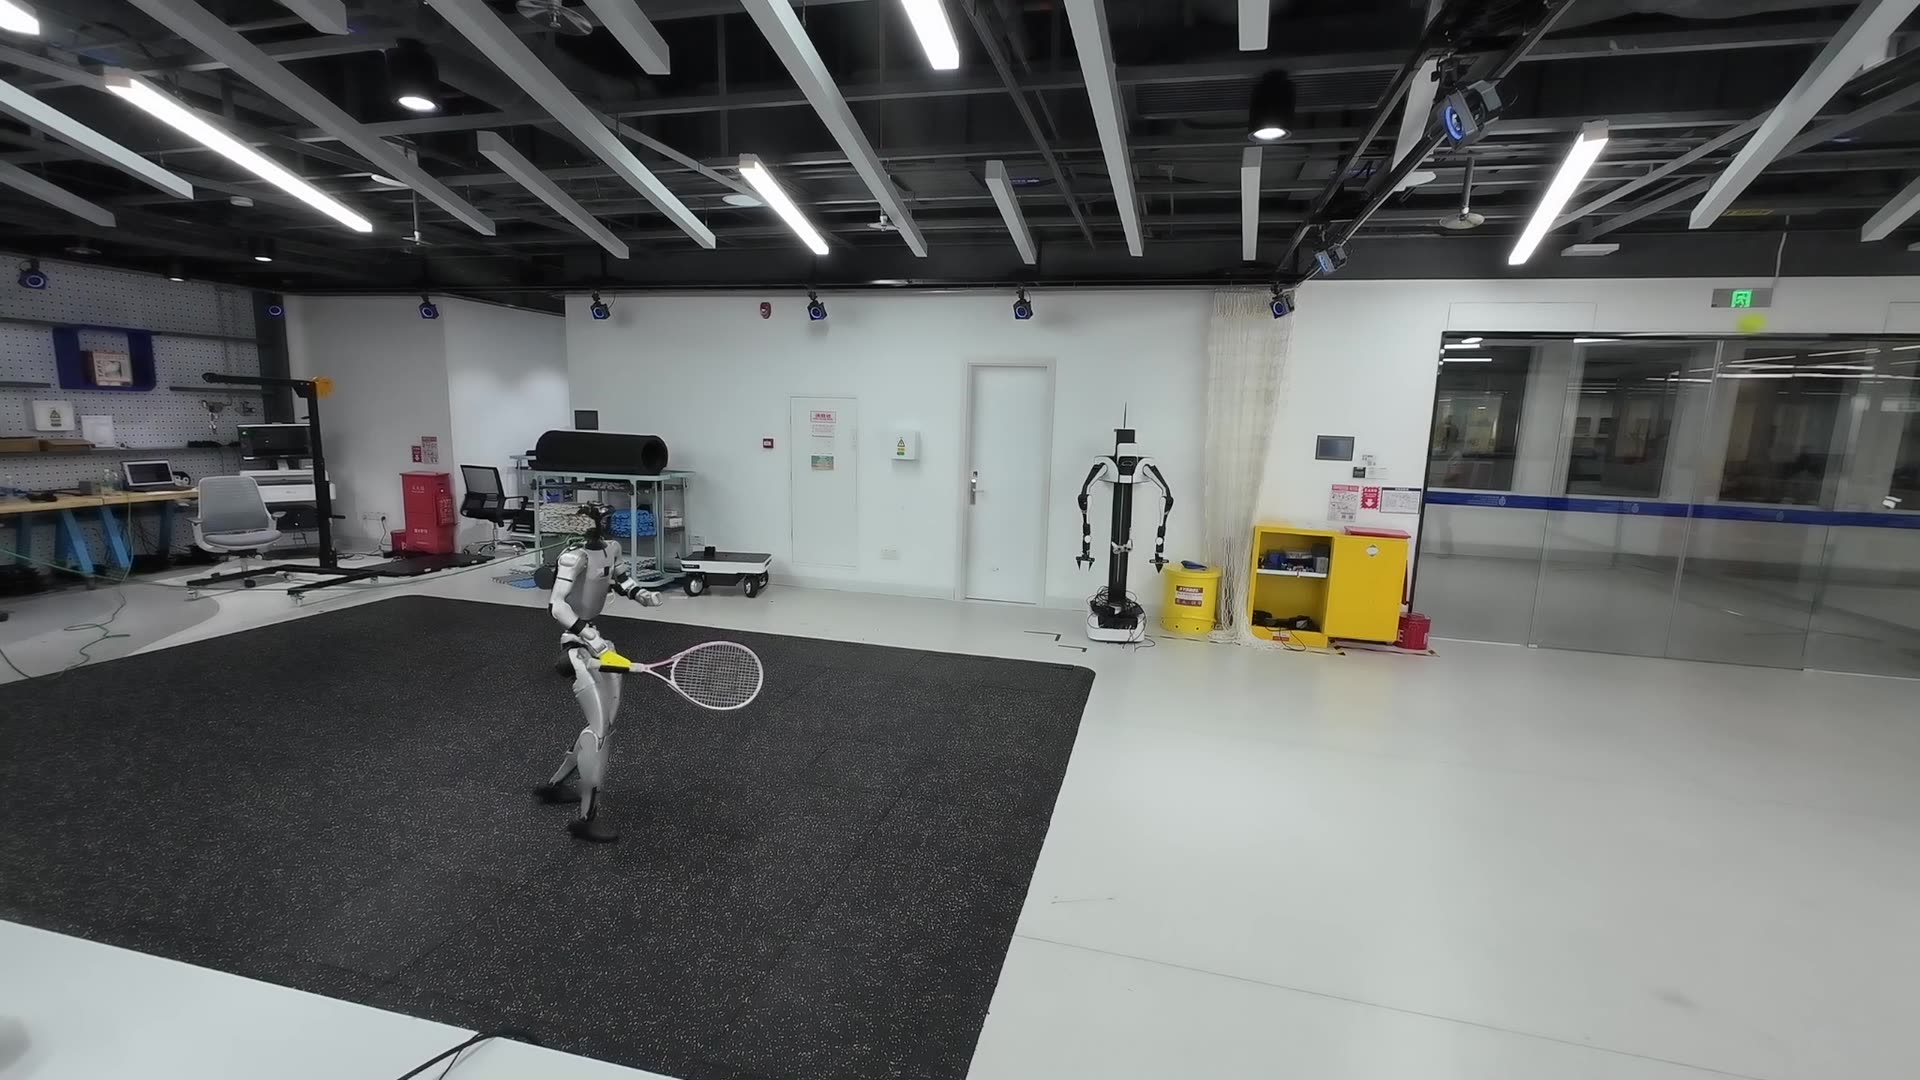
Reactive humanoid tennis · Real-world experiments
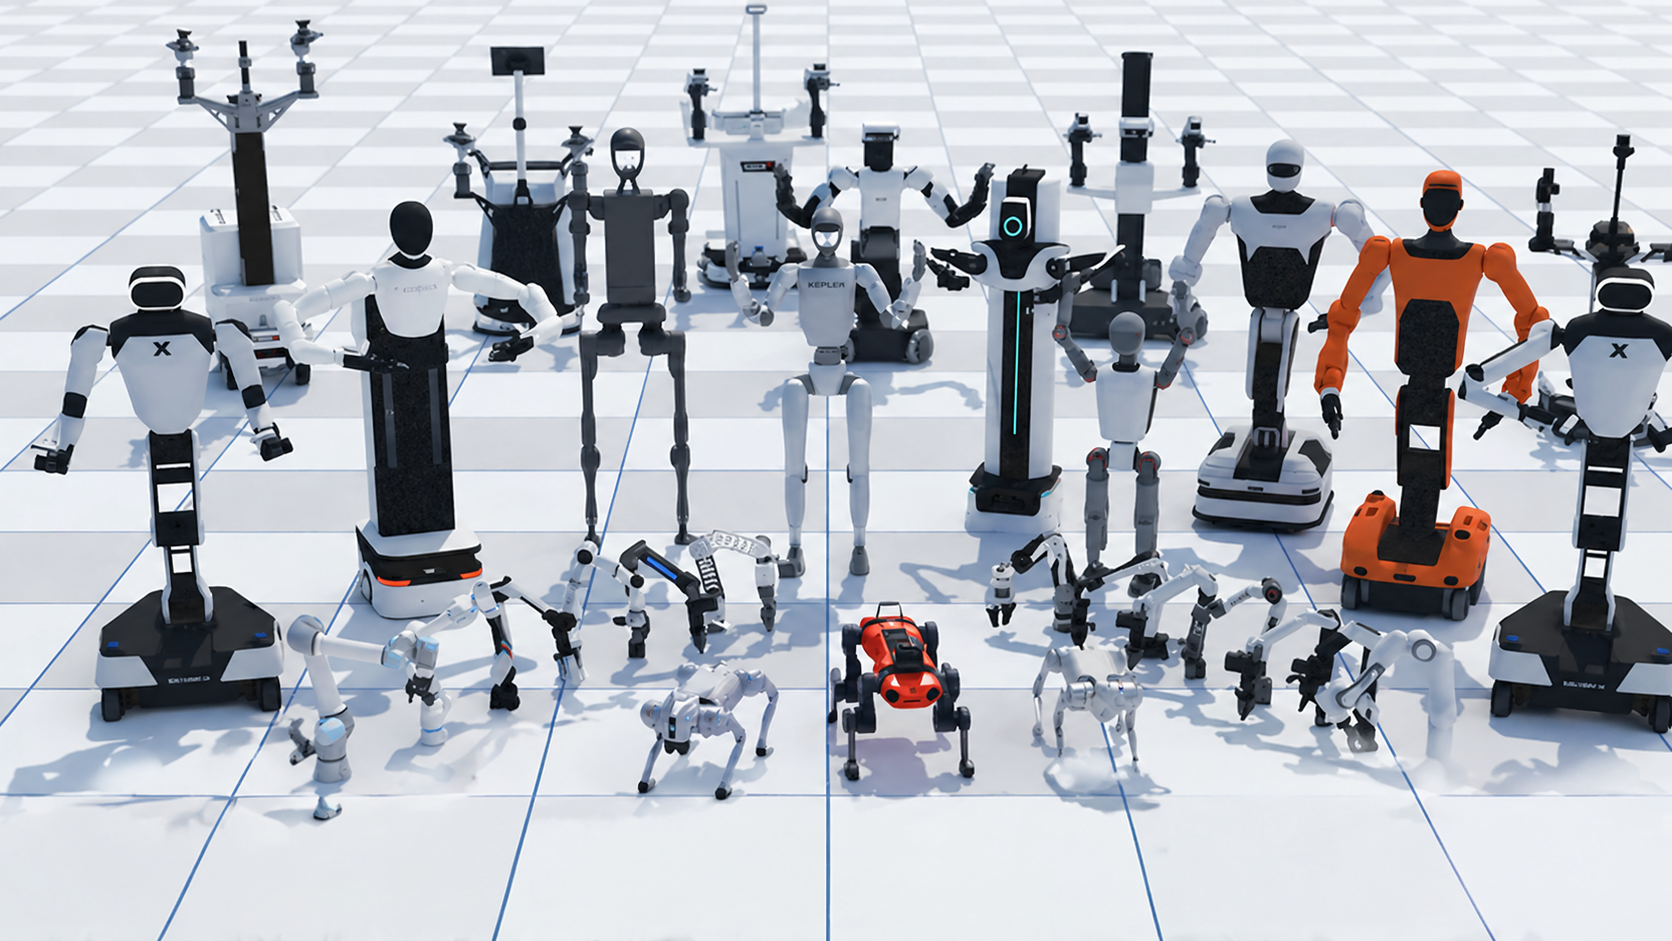
Photorealistic simulation · Vision-informed robot learning
Research interests
- Perception-driven whole-body control and dynamic humanoid interaction
- Reinforcement learning, motion imitation, and sim-to-real transfer
- Multi-robot collaboration and world models for loco-manipulation
I also share Isaac Lab tutorials on Bilibili, with 3k subscribers and over 100k views.
selected publications
- One Motion, Diverse Strokes: A Kinematics-Aware Adaptive Event Prior for Vision-Guided Humanoid Tennis Striking2026Under review.