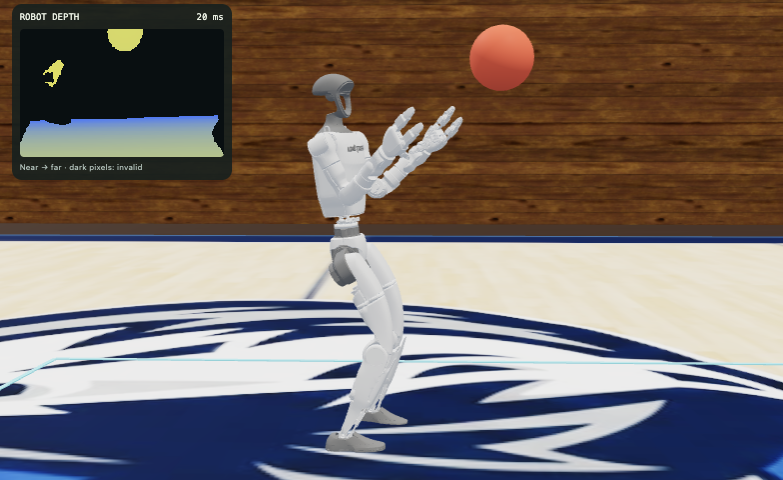
research SwiftCatch Egocentric Agile Whole-Body Ball Catching for Humanoid Robots. MultiMimic Multi-robot collaborative loco-manipulation via a differentiable world model. APOLLO Perception-driven control for long-horizon loco-manipulation. Whole-body teleoperation Human-centric whole-body teleoperation for Unitree G1 using Apple Vision Pro.